01
Pin Map and Contact Functions
Define the function of each power, return, signal, control or detection contact.
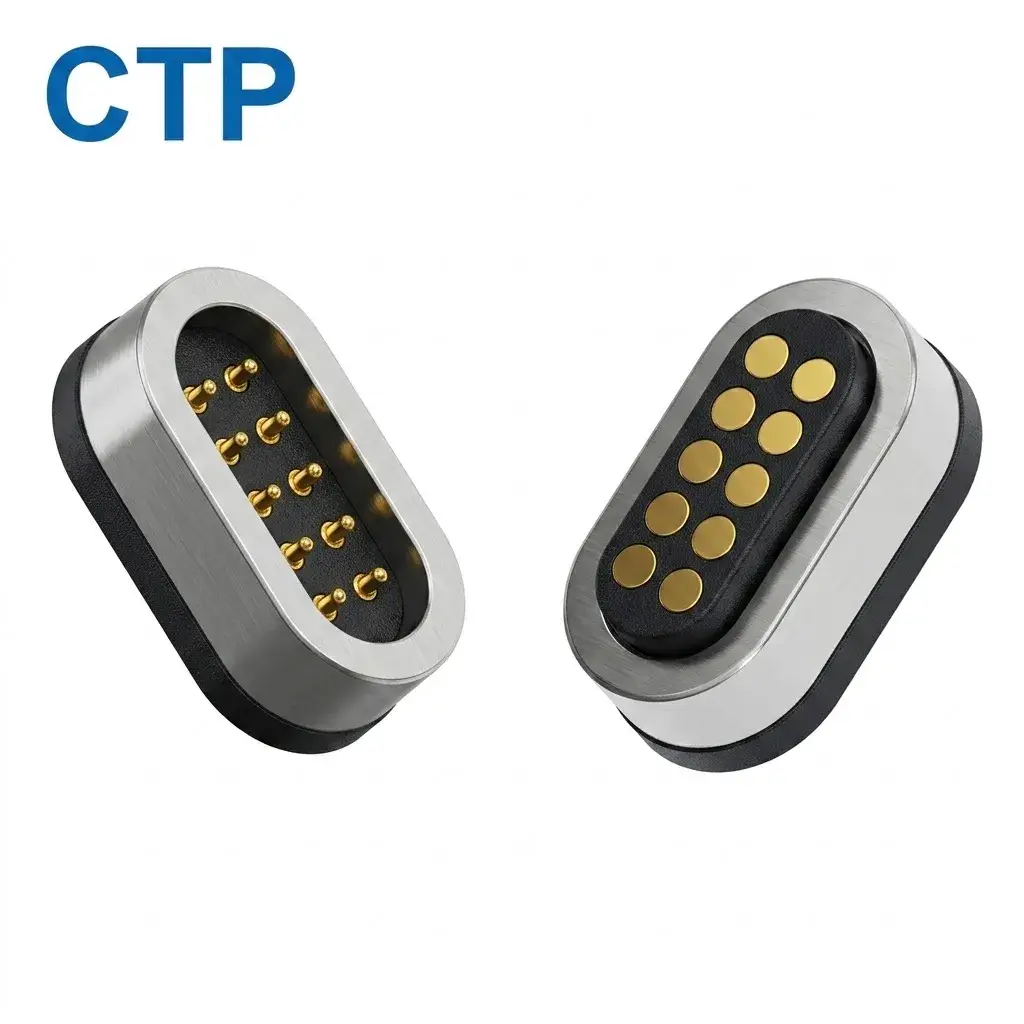
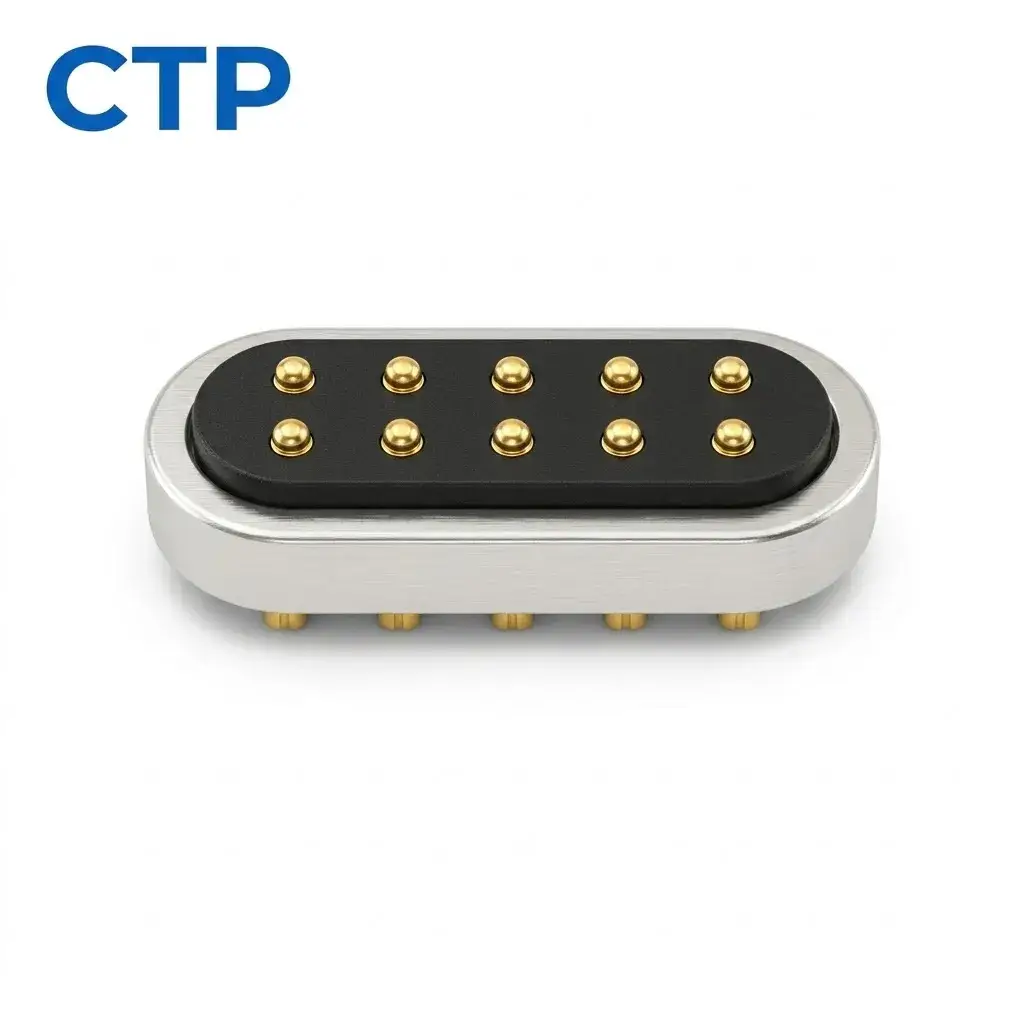
CTP 10 Pin Dual Row Magnetic Pogo Pin Connector Pair uses a compact 5+5 contact arrangement with a 2.0 mm pitch, metal housing, spring-loaded pogo pin side and flat target side. The ten contacts can be assigned to power, return, detection, identification and project-specific signal functions according to the customer Pin Map. Final voltage, current, working stroke, magnetic retention, data capability, mating life and environmental performance are confirmed through approved drawings and complete-device validation.
Product specifications should be reviewed together with the customer device, PCB, electrical assignment and mechanical mating conditions.
Define the function of each power, return, signal, control or detection contact.
Provide voltage, continuous current, peak current and required signal conditions.
Provide available length, width, height, PCB area and required mating orientation.
Provide application, expected quantity, environment and customer validation requirements.
Review the product-specific description, technical parameters, contact arrangement, mechanical structure and project conditions below.
Engineering Summary: The CTP 10 Pin Dual Row Magnetic Pogo Pin Connector Pair uses a compact 5+5 contact arrangement with a 2.0 mm pitch, a metal housing, a spring-loaded pogo pin side and a flat target side. The ten contacts can be assigned to project-specific power and signal functions, but pin count alone does not establish current rating, voltage, protocol compatibility, magnetic force, mating life or environmental protection.
This 10 pin magnetic pogo pin connector is designed for compact devices that require more electrical contact positions than a conventional single-row magnetic connector can provide within the available interface area.
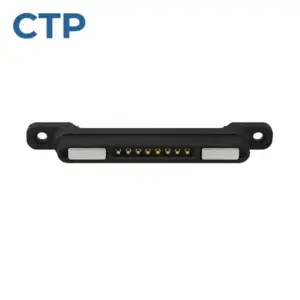
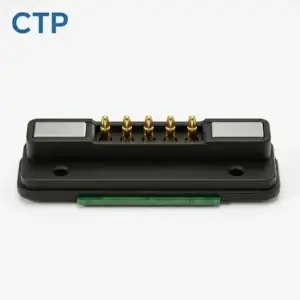
The product shown uses a dual-row 5+5 contact arrangement. One connector half contains ten spring-loaded pogo pin contacts, while the opposing half provides ten flat mating targets.
Permanent magnets integrated into the connector structure may assist approach and retention. The final position, contact compression and load path should still be controlled by the connector housings, locating features and customer-device structure.
Final performance must be confirmed using the approved connector drawing, customer Pin Map, PCB layout and complete mating assembly.
| Connector Element | Product Structure | Engineering Requirement |
|---|---|---|
| Contact Count | 10 electrical contacts | Define the function and electrical state of every contact |
| Contact Layout | Dual-row 5+5 arrangement | Confirm row spacing, contact pitch and alignment tolerance |
| Pogo Pin Side | Ten spring-loaded contacts | Define working stroke, contact force and termination |
| Target Side | Ten flat mating contacts | Define target material, finish, flatness and mechanical support |
| Housing | Oval metal housing with insulating contact insert | Define mounting, grounding, insulation and enclosure integration |
| Magnetic Structure | Integrated magnetic capture and retention | Define capture, seated retention and separation requirements |
| Termination | Project-specific PCB, FPC, wire or subassembly integration | Confirm using the approved drawing and customer assembly |
The pitch value should be defined using the approved product drawing. In a dual-row connector, two different dimensions may be relevant:
A general “2.0 mm pitch” statement should not be used as a substitute for a complete dimensional drawing.
The drawing should identify:
A 10 pin connector provides ten conductive contact positions. The actual number of electrical functions depends on the Pin Map.
Some contacts may be used independently, while other contacts may be connected in parallel for power or return paths.
| Possible Contact Function | Engineering Definition Required |
|---|---|
| Power input or output | Voltage, continuous current, peak current and power-enable state |
| Power return | Return-path capacity, PCB routing and contact sequence |
| Device detection | Initial presence or verified full-seating condition |
| Accessory identification | Resistor identification, analog level or digital communication |
| Control signal | Logic voltage, reference path and fault state |
| Temperature or fault signal | Sensor location, signal range and response logic |
| Project-specific communication | Physical layer, data rate, return path and protection |
| Factory or service contact | Access state, security and intended fixture |
The following allocation is an engineering example only. It is not a fixed Pin Map for every connector.
| Contact Group | Example Function | Required Validation |
|---|---|---|
| Pins 1–2 | Parallel positive power contacts | Current sharing, voltage drop and individual temperature rise |
| Pins 3–4 | Parallel power-return contacts | Return-path capacity and contact-sequence behaviour |
| Pin 5 | Accessory detection | Partial-mating and false-detection conditions |
| Pin 6 | Accessory identification | Identification tolerance and wrong-accessory response |
| Pins 7–8 | Project-specific differential or paired signal | Physical layer, return environment and channel testing |
| Pins 9–10 | Control, sensing or service functions | Logic levels, protection and disconnection behaviour |
The final allocation must be developed from the actual host and accessory circuits.
| Interface Architecture | Possible Contact Allocation | Primary Design Focus |
|---|---|---|
| Multi-contact charging interface | Parallel power and return contacts plus detection and identification | Current sharing, voltage drop, temperature rise and sequencing |
| Power and low-speed communication | Power contacts plus control, sensing and communication contacts | Logic levels, reference paths and fault recovery |
| Docking interface | Power, detection, identification and accessory control | Partial mating, exposed contacts and user-removal states |
| Industrial control interface | Power plus several project-specific control or sensor signals | Vibration, contamination, shielding and grounding |
| High-speed project interface | Power, return, differential pairs and control contacts | Signal integrity, PCB transitions and complete channel validation |
Ten contacts may provide enough conductors for several possible communication architectures, but the connector does not automatically support USB, video or another high-speed protocol.
High-speed performance depends on the complete channel:
Host PHY → Host PCB → Protection Components → Connector Contacts → Mating Targets → Accessory PCB → Accessory PHY
Relevant channel requirements may include:
Low contact resistance and ten visible contacts do not independently prove high-speed data performance.
| Parameter | Product Definition |
|---|---|
| Product Type | 10 pin dual row magnetic pogo pin connector pair |
| Contact Arrangement | 5+5 dual-row layout |
| Nominal Pitch | 2.0 mm configuration; verify contact and row spacing by drawing |
| Mating Structure | Spring-loaded pogo pin side with flat target side |
| Housing | Metal housing with insulating contact insert |
| Pin Map | Project-specific power, return, detection, identification and signal allocation |
| Overall Dimensions | Confirm using the approved product drawing |
| Working Stroke | Confirm minimum, nominal and maximum pogo pin compression |
| Contact Force | Report at a defined working stroke |
| Voltage | Defined according to the selected connector and complete circuit |
| Continuous Current | Confirm per contact through voltage-drop and temperature-rise testing |
| Contact Resistance | Report with test current, stroke, target, sample state and measurement method |
| Magnetic Performance | Capture, seated retention and separation force are specified separately |
| Mating Life | Defined by stroke, load, target, environment and acceptance criteria |
| Contact Finish | Confirm separately for pogo pins, targets and terminations |
| Ingress Protection | Applies only to a defined and tested connector or complete device assembly |
| Environmental Testing | Test method, exposure, sample state and acceptance criteria must be defined |
| Termination | PCB, FPC, wire or project-specific subassembly integration |
The magnetic structure may draw the two connector halves together, but magnetic attraction should not be the only feature controlling the final contact position.
| Interface Function | Recommended Control |
|---|---|
| Initial capture | Magnet arrangement and approach geometry |
| Connector orientation | Asymmetric housing, keyed features and magnetic polarity |
| Final alignment | Housing guides, mating faces and mechanical datums |
| Pogo pin compression | Mechanical stops and dimensional tolerance stack |
| Seated retention | Magnetic structure and customer mechanical support |
| Connector removal | Defined separation direction and release-force requirement |
Capture force, seated retention and separation force should be measured separately because they describe different connector behaviours.
A simplified working-stroke calculation is:
S = Hfree - Hseated
where:
The complete tolerance stack may include:
| Stroke Condition | Possible Result |
|---|---|
| Insufficient compression | Intermittent power, unstable detection or resistance variation |
| Approved working stroke | Intended contact force and electrical condition |
| Excessive compression | Spring bottoming, target damage, housing load or PCB stress |
| Unequal compression between contacts | Different contact resistance and uneven current distribution |
A 10 pin connector may use multiple contacts in parallel to increase the available power-path capacity. Parallel contacts do not automatically divide current equally.
Current sharing can be affected by:
A simplified relationship for two parallel contacts is:
I1 / I2 = R2 / R1
The lower-resistance path may carry more current and generate more local heat. Individual contact current and temperature should therefore be evaluated under the maximum intended load.
A simplified connector power path is:
Rpath = Rhost-PCB + Rtermination1 + Rpogo + Rinterface + Rtarget + Raccessory-PCB
The voltage drop is:
Vdrop = I × Rpath
The resistive power loss is:
Ploss = I² × Rpath
The project should define:
The current capacity of the connector cannot be determined from the number of contacts or product appearance alone.
The magnets may retain the connector close to its intended position before all ten contacts reach their approved working stroke.
| Partial-Mating Condition | Possible Risk | Required Review |
|---|---|---|
| One side contacts first | Unexpected power or signal sequence | Approach angle and contact-height tolerance |
| Laterally offset mating | A pogo pin reaches an adjacent target | Target dimensions, spacing and maximum offset |
| Magnetically retained but not seated | False device detection or unstable power | Independent electrical seating verification |
| Wrong connector orientation | Incorrect Pin Map or reversed electrical state | Mechanical and magnetic polarization |
| Conductive contamination | Short circuit or leakage between dense contacts | Power control and foreign-object protection |
| Removal under load | Transient voltage, arcing or communication interruption | Power-disable sequence and powered-endurance testing |
A dual-row 10 contact interface has smaller clearances between adjacent targets than a low-pin-count connector.
Possible contamination includes:
The product design should review contact spacing, recessed geometry, normally de-energized states, current limiting, inspection access and approved cleaning methods.
| Application | Possible Connector Role | Primary Engineering Focus |
|---|---|---|
| Multi-function charging dock | Power, detection, identification and accessory control | Current sharing, partial mating and power sequencing |
| Industrial handheld terminal | Docking, charging, communication or service interface | Vibration, contamination and fixture alignment |
| Detachable control module | Power and several control or sensor signals | Mechanical support, Pin Map and connection sequence |
| Portable electronics accessory | Power, identification and project-specific communication | Connector size, removal and exposed-contact safety |
| Smart-home or IoT device | Docking, power and accessory communication | Long-term contact stability and cleaning |
| Custom consumer electronics | Compact proprietary power and signal interface | Compatibility, service strategy and validation |
These are possible application categories rather than guaranteed uses of every connector configuration.
| Requirement | Recommended Evaluation |
|---|---|
| Pin Map | Confirm the function and electrical state of all ten contacts |
| Dimensions and Pitch | Verify same-row pitch, row spacing and target positions |
| Working Stroke | Verify minimum, nominal and maximum compression |
| Contact Force | Measure the force-versus-stroke response |
| Contact Resistance | Measure with a defined current, target, stroke and sample condition |
| Voltage Drop | Measure the complete power path at intended current |
| Temperature Rise | Evaluate individual contacts, terminations, PCB and housing |
| Parallel Current Sharing | Measure individual contact current and temperature |
| Magnetic Capture | Evaluate approach and orientation behaviour |
| Retention and Release | Measure force in defined directions |
| Partial Mating | Test tilted, offset and magnetically retained but unseated states |
| Wrong Orientation | Evaluate mechanical fit, polarity and electrical response |
| Short Circuit | Evaluate adjacent-contact bridging, moisture and conductive objects |
| Low-Speed Signals | Verify protocol operation, interruption and reconnection |
| High-Speed Signals | Evaluate loss, return loss, crosstalk, skew and interoperability |
| Mechanical Endurance | Use defined stroke, speed, target and acceptance criteria |
| Powered Endurance | Evaluate mating and separation under the intended electrical state |
| Environmental Exposure | Test representative dust, moisture, vibration and cleaning conditions |
| Production Variation | Evaluate contacts, targets, housings, magnets and assembled tolerances |
| Input | Information to Provide |
|---|---|
| Pin Map | Function of all ten contacts |
| Electrical Conditions | Voltage, continuous current, peak current and signal types |
| Communication | Detection, identification, low-speed or high-speed physical layer |
| Mechanical Space | Maximum length, width, height and restricted regions |
| Pitch Requirement | Same-row contact pitch and distance between rows |
| Mating Direction | Approach, final seating and removal direction |
| Working Stroke | Minimum, nominal and maximum compression |
| Termination | PCB, FPC, wire or project-specific subassembly |
| Magnetic Requirements | Capture, seated retention and release-force conditions |
| Environment | Temperature, moisture, dust, vibration and cleaning exposure |
| Durability | Mating frequency, powered removal and acceptance criteria |
| Project Files | 2D drawing, 3D model, schematic, PCB layout or device assembly |
| Commercial | Prototype quantity, annual forecast and project stage |
The product image shows a spring-loaded pogo pin side and a flat target side. The final supplied scope should be confirmed in the quotation and approved drawing.
The connector uses a dual-row 5+5 contact layout. The same-row pitch and distance between the two rows should be confirmed by the approved drawing.
Yes, the contacts can be allocated to project-specific power, return, detection, identification and signal functions. The final Pin Map must be defined by the customer circuit.
Not necessarily. Some contacts may be used for power, return, detection, shielding or parallel current paths.
No. USB compatibility depends on the complete controller, PCB routing, connector channel, protection components and protocol validation.
No universal rating should be assumed. Voltage and current depend on the contact allocation, working stroke, termination, PCB routing and thermal environment.
Not automatically. Differences in compression, resistance, contamination and PCB routing can produce unequal current distribution.
Initial capture, seated retention and connector separation should be specified and measured separately in their defined directions.
No. Any ingress-protection claim must identify the exact tested connector or complete enclosure, mating state and test condition.
Provide the ten-contact Pin Map, electrical conditions, signal types, available space, pitch requirements, working stroke, magnetic requirements and available 2D or 3D drawings.
Review additional custom magnetic connector components for different contact counts and mechanical structures.
Submit the device model, Pin Map, electrical conditions, available space and drawings through the Get Quote & Samples page .
CTP can review the 5+5 contact layout, contact pitch, pogo pin working stroke, mating targets, magnetic arrangement, housing structure and PCB, FPC or wire termination. Final electrical ratings, signal performance, mating life, environmental protection and complete device performance must be confirmed through approved drawings and project-specific validation.
This product page presents a CTP magnetic connector configuration for engineering reference. Final dimensions, electrical ratings, materials, magnet structure, sealing level and reliability targets are not universal values; they are confirmed against the approved drawing, installation condition and model-specific validation plan.
CTP reviews the application and prepares a drawing or specification for approval before sample production. Test scope, acceptance criteria and report format should identify the model, sample status, method, conditions, result and review date.
Yes. Customization can cover geometry, contact layout, materials, cable construction, magnetic structure, sealing and appearance. Feasibility depends on the application and approved specification.
No. Current, voltage, resistance, temperature rise and ingress-protection claims apply only to the identified model and stated test conditions.
Timing is confirmed after the drawing, materials, tooling, sample quantity, validation scope and production requirements have been reviewed.
Submit your Pin Map, electrical requirements, available space, mating structure and project quantity for connector selection or custom development review.
Use the following engineering guides to compare contact count, contact allocation and connector layout before confirming the final product or customized design.
Review the complete selection path from contact count and electrical functions to connector shape.
View Main Guide →Compare one-contact special structures, complete two-contact circuits and third-contact functions.
Compare Low-Pin Designs →Determine whether four contacts are sufficient or whether a defined fifth electrical path is required.
Compare 4 Pin and 5 Pin →Calculate the contact budget and compare six-contact, multi-row and customized contact-array structures.
Compare High-Pin Designs →